
Autonomous driving & mapping
Camera, LiDAR and event data for navigation, at volume.
Bounding boxes, point cloud cuboids, lanes and events for driving and mapping models, with data residency handled.
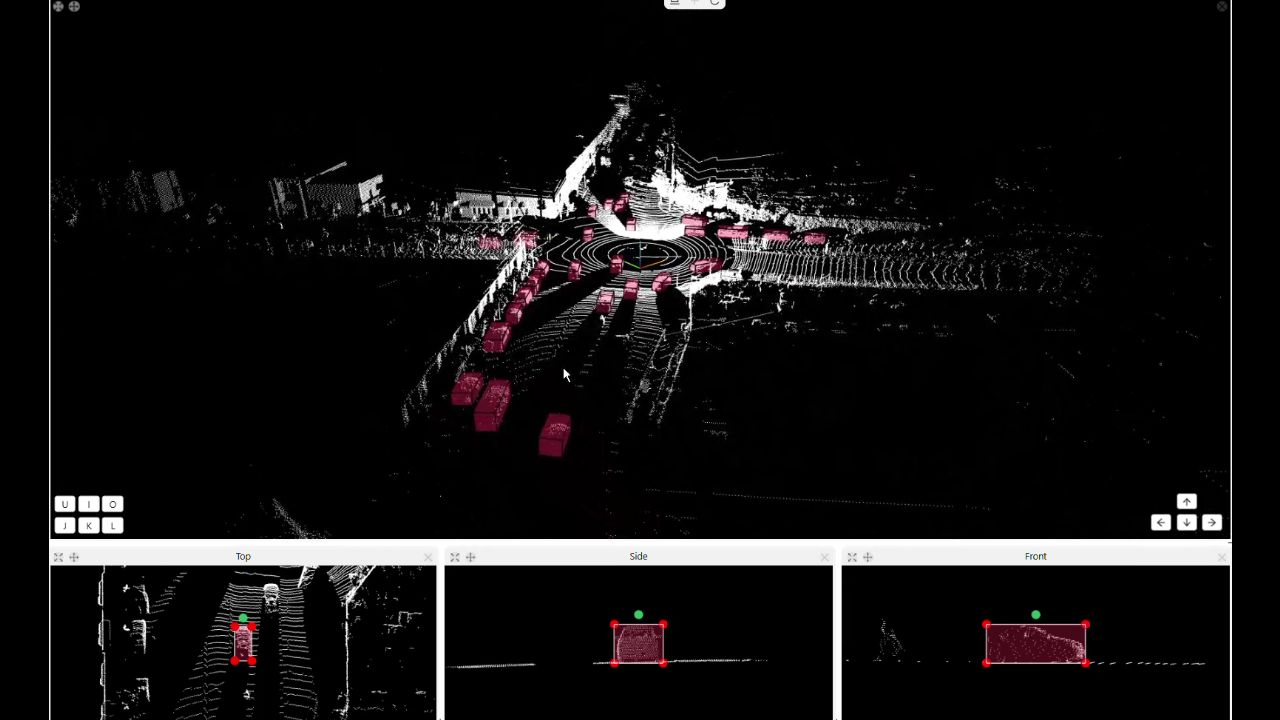
From the sensor log to the map
Every part of the workflow where we can take work off your team.
Perception
3D and fusion
Mapping
Scenarios
We work with video, LiDAR, point cloud and GPS.
What we label
Every class is written into a guide with your team before the first batch. Files come back as COCO JSON, YOLO, Pascal VOC, CSV, JSONL or your own schema.
Camera
Road users
Bounding box and track ID
Car, truck, pedestrian, cyclist, scooter
Road surface
Polyline and segmentation
Lane line, curb, crosswalk, drivable area
Signs and lights
Bounding box and class
Sign type, light state
LiDAR and point cloud
Objects
3D cuboid and track ID
Vehicle, pedestrian, cyclist, barrier
Scene
3D segmentation
Ground, building, vegetation, pole
Video and logs
Events
Time span
Cut in, hard brake, near miss, lane change
Coordinates
Geotag
Location, heading, point of interest
How we test the model
The tests that matter for autonomous driving & mapping models, and what you get back from each.
Hard case quality
Night, rain, glare and occlusion sets reviewed apart from easy footage.
You get backPrecision and recall by condition
Tracking consistency
Object IDs checked across frames and sensors.
You get backID switches per sequence
Map accuracy
Lane and road geometry checked against reviewed ground truth.
You get backGeometry error by feature
Where autonomous driving & mapping teams start
Problems teams bring us, and the first piece of work we would scope.
Your data has to stay in the EU, but the team that labels it does not.
What we doWe work on your servers under the residency rules you set, as we did for Client C.AnnotateThe model handles daytime highways and struggles at night in the rain.
What we doHard case sets labelled and reported separately, so the gap is visible.Evaluate & alignCuboids drift between camera and LiDAR.
What we doFused labelling with alignment checks on every sequence.AnnotateRelated work
Half a million images for autonomous navigation, with every file kept on EU servers
2,000 robot videos described every week by a team built in seven days
Twelve times the volume in five weeks, with quality holding at 95 to 98%
Human in the loop support for visual deviation detection on production lines, with a response time requirement under two minutes.
24/7 live review for production line visual AI, quality above 95% by month two
Bring us the autonomous driving & mapping data your model gets wrong.
Send a small batch and get it back done, free, usually within 24 to 48 hours. You judge the work before you pay for anything.